
Explore AERISE work across delivered platforms and facilities, system demonstrations, hands-on education and research partnerships. See the task, our role and the documented outcome for each example.
Delivered systems & facilities
Platforms and institutional spaces supplied, designed or built by AERISE.
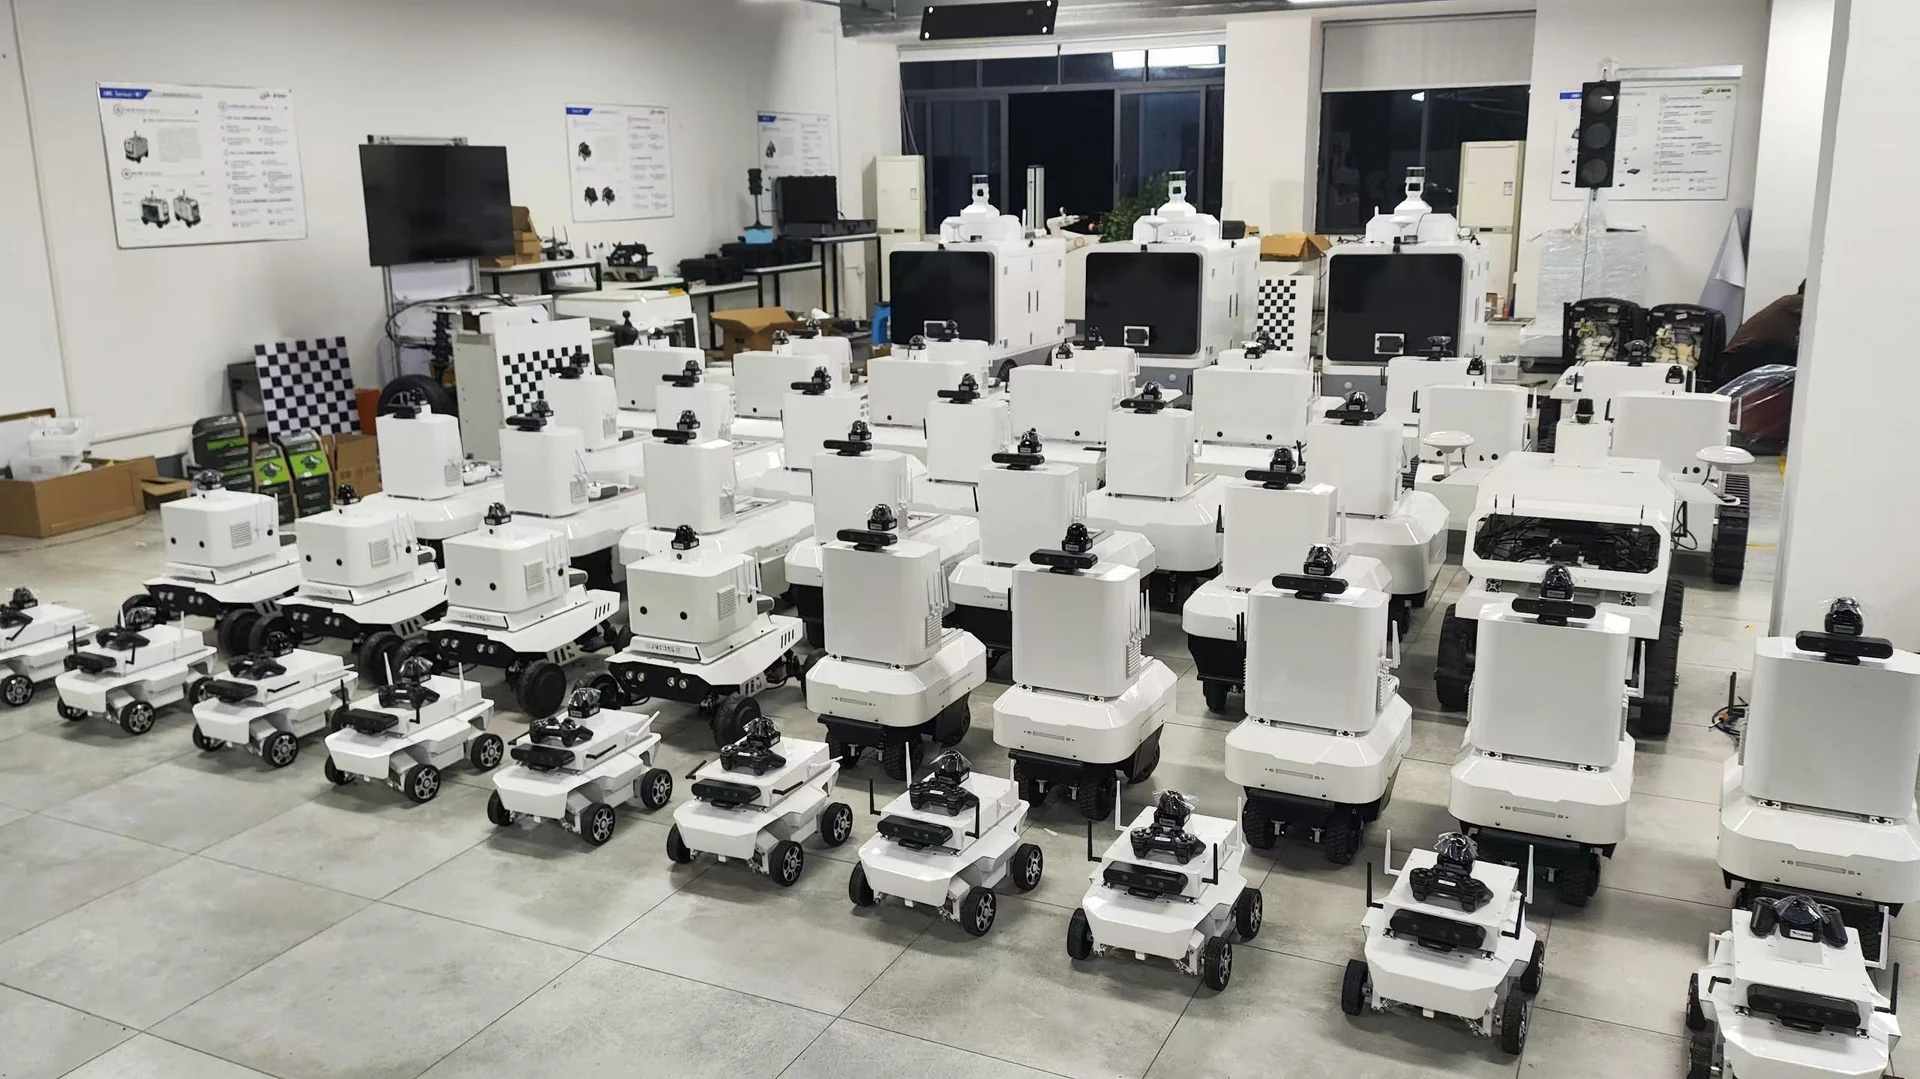
Platform delivery
University UGV fleet delivery
- Context
- A university robotics environment.
- The task
- Provide ground robot platforms in multiple configurations.
- AERISE role
- Delivered compact mobile bases together with larger wheeled and tracked configurations.
- Outcome
- A delivered fleet documented in photographs from the university site.

Institutional facility · 2026
Retractable robotics activity zone
- Context
- A Singapore polytechnic classroom.
- The task
- Allow one room to support both open teaching and controlled robotics activities.
- AERISE role
- Designed a flexible activity zone with three independently retractable net sides, coordinated with the room and teaching workflow.
- Outcome
- Nets can be raised for an open classroom or deployed around the planned activity.

Completed facility
Institutional indoor drone cage
- Context
- A Singapore polytechnic teaching and training space.
- The task
- Create a dedicated controlled area for practical UAV education and training.
- AERISE role
- Designed and built the enclosure around the available room, intended aircraft and day-to-day teaching environment.
- Outcome
- A completed indoor cage, including protective netting, access and integration with the room.
System demonstrations
Working demonstrations of integrated capabilities for further task-specific development.
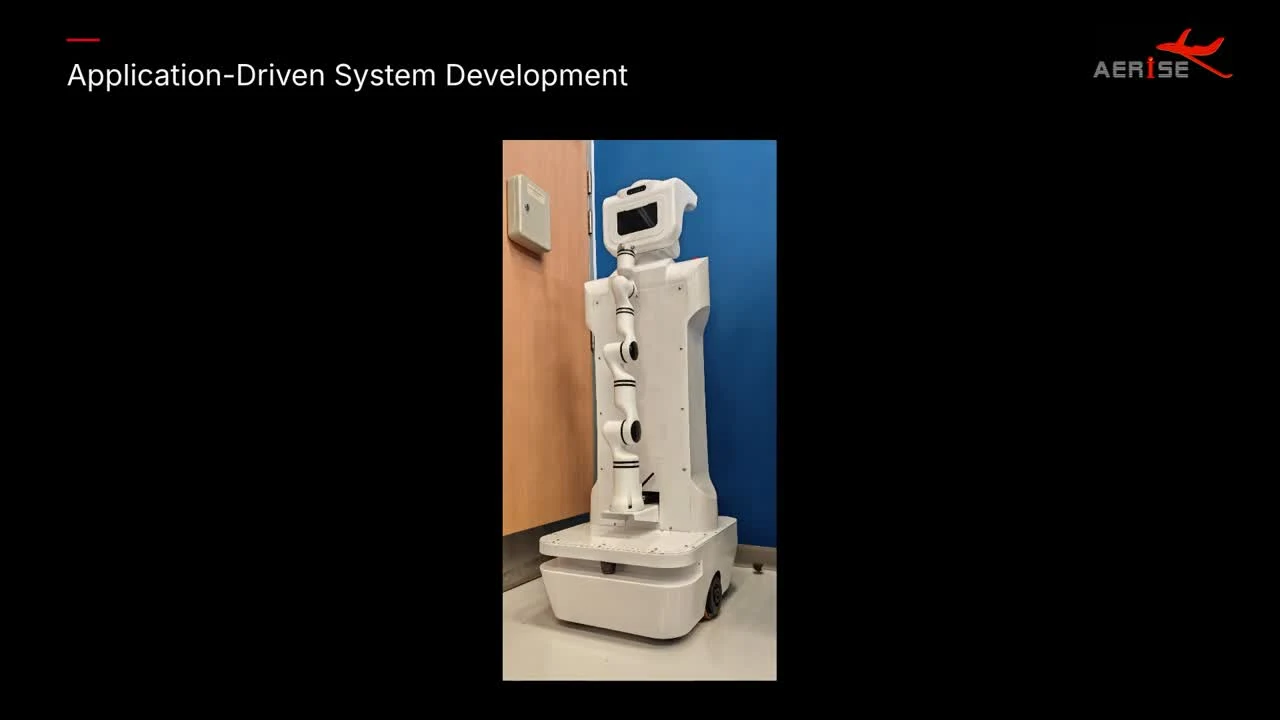
System demonstration
Mobile manipulation: navigate, identify, pick
- Context
- Research and education-oriented mobile manipulation.
- The task
- Reach a target location, identify the intended object and execute a grasp.
- AERISE role
- Integrated AMR navigation, real-time mapping, YOLO-based recognition, a robotic arm and gripper.
- Outcome
- A 66-second demonstration of mobility, visual recognition and object grasping.
Education & workshops
Hands-on programmes connecting code, hardware and real-world experimentation.
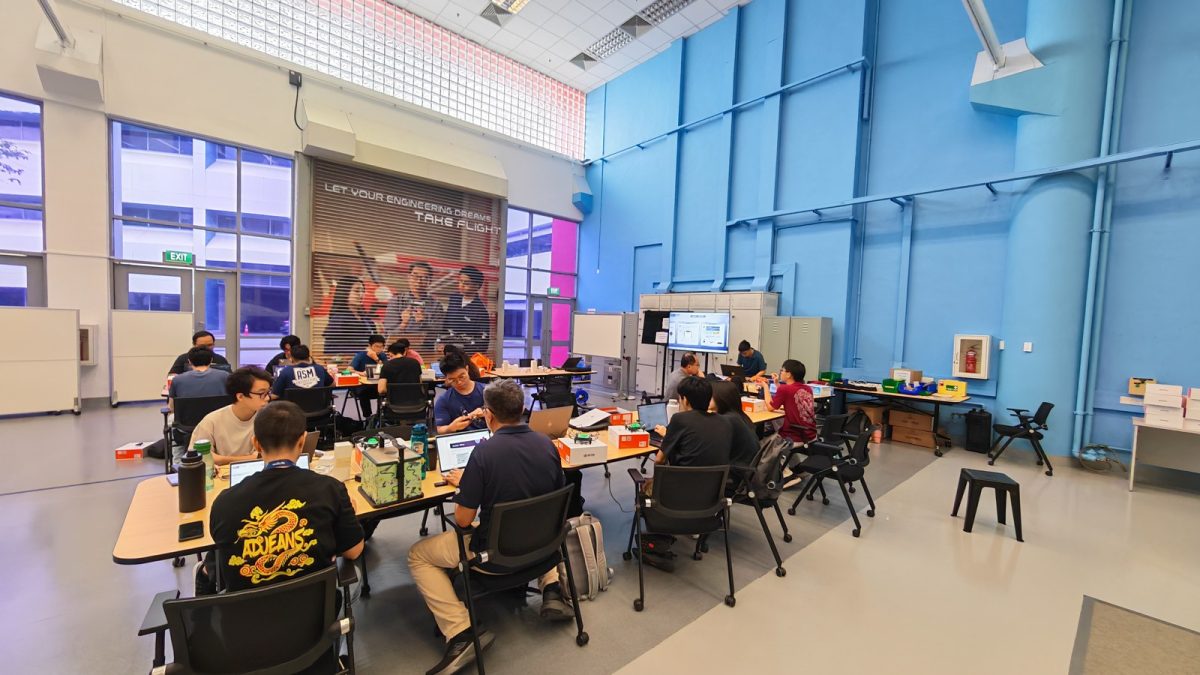
Teaching programme · 2026
NYP multi-drone workshop
- Context
- Students and educators at Nanyang Polytechnic; 31 August 2026.
- The task
- Connect UAV programming concepts with testing, flight behaviour and multi-drone activities.
- AERISE role
- Conducted a four-session hands-on programme using the HULA drone platform.
- Outcome
- Guided coding, system testing and flight activities progressing towards coordinated drone operation.
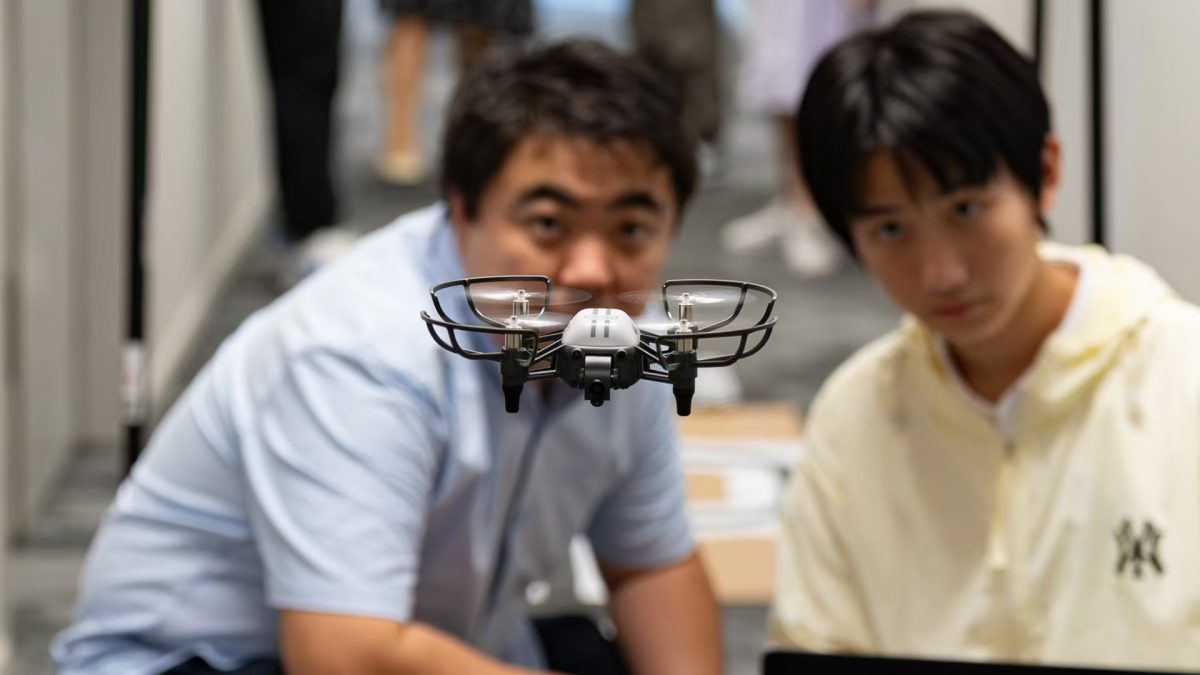
STEM programme · 2025
Singapore STEM Study Tour
- Context
- International learners taking part in STEM activities in Singapore.
- The task
- Introduce aerospace and engineering through practical, collaborative activities.
- AERISE role
- Delivered a programme combining lessons, educational drone programming and interactive challenges.
- Outcome
- Hands-on activities included paper-plane learning, obstacle navigation and laser-tag challenges.
Collaboration & research support
Partner demonstrations and support for the wider robotics research community.

Partner showcase · 2025
AERISE & CHINGMU at IROS 2025
- Context
- Joint showcase with CHINGMU Vision at IROS in Hangzhou.
- The task
- Demonstrate optical motion tracking alongside robotic and aerial systems.
- AERISE role
- Contributed robotics and control experience and supported aerial swarm and robotic demonstrations.
- Outcome
- Live tracking, robotics and drone demonstrations at the joint booth.

Research event sponsorship · 2024
CARIC Challenge at IROS 2024
- Context
- International teams researching cooperative multi-UAV inspection.
- The task
- Evaluate and exchange approaches to inspection with multiple aerial robots.
- AERISE role
- Supported the Cooperative Aerial Robots Inspection Challenge through sponsorship.
- Outcome
- Participating teams demonstrated inspection approaches and shared their research; these were the teams’ systems.
System demonstration / Mobile manipulation
Navigate. Identify. Pick.
An AMR, a robotic arm and a gripper — brought together with real-time mapping and YOLO-based vision to connect mobility with purposeful manipulation.
The task
Reach the right place.
Pick the right object.
Move to a required location, identify whether an object matches the intended target, and execute the grasp with a robotic arm and gripper.
AERISE integration
Mobility meets perception
and manipulation.
The system brings AMR navigation, real-time map-based localization, YOLO object recognition and arm-and-gripper operation into one mobile manipulation platform.
Reach the destination.
The AMR uses a real-time map to localize and navigate to the required location.
Recognize the target.
YOLO-based vision identifies objects and determines whether they match the intended target for picking.
Act on what is seen.
The robotic arm and gripper execute the grasp, translating target identification into physical action.
Demonstrated capability
From movement to interaction.
The demonstration shows map-based mobility, visual target identification and object grasping on a mobile robotic platform — a practical foundation for developing task-specific manipulation workflows.
Your next robotics project
Start with the task.
Tell us what your robot needs to do, where it will operate and which platforms you need to connect.